C++ · ROBOTICS · OPEN SOURCE
Path planning with Voronoi diagrams.
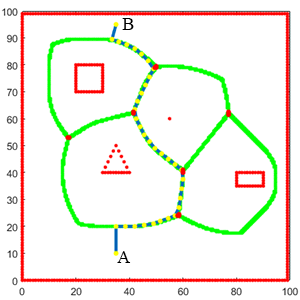
A path-planning algorithm connecting two points on a map with walls and obstacles, favoring routes that stay clear of obstacles.
METHOD
Constructing a Voronoi diagram and finding a path between A and B.
TOOLS
C++ source code and a Matlab/Octave script for visualizing results.
Planning the route
The map’s Voronoi diagram provides the basis for finding the robot’s path. The goal is to maintain greater clearance from obstacles and reduce collision risk along the route.
The project is open source: the repository includes code, comments, and a script for visualizing the map and the computed path.
Project screenshots